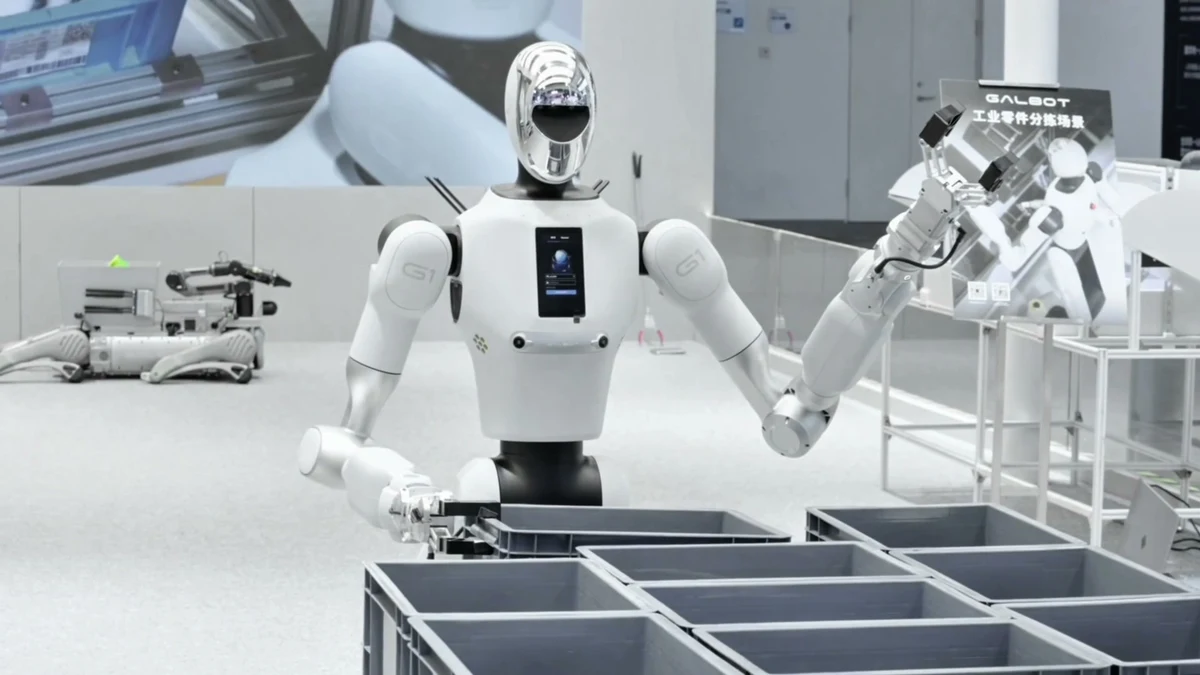
At Web Summit 2026 in Lisbon, Beijing-based robotics pioneer Galbot (Galaxy General Robot) took center stage with an unequivocal industry message: general-purpose humanoid robots are no longer confined to staged laboratory demos. Under the official session title “The robots have clocked in,” Galbot Chief Strategy Officer Yuli Zhao demonstrated how their flagship Galbot G1 wheeled humanoid has graduated into continuous, unstaffed commercial duty across urban retail, hospital pharmacies, and industrial manufacturing facilities.
While much of the global humanoid conversation remains dominated by dynamic bipedal platforms from Tesla, Boston Dynamics, and Unitree, Galbot has adopted a pragmatic hybrid engineering philosophy. By mounting an expressive biological torso, dual dexterous arms, and a telescoping spine onto an omnidirectional wheeled base, the G1 delivers what commercial enterprise buyers demand right now: rock-solid physical stability, 8 hours of uninterrupted battery endurance, and zero risk of catastrophic falling.
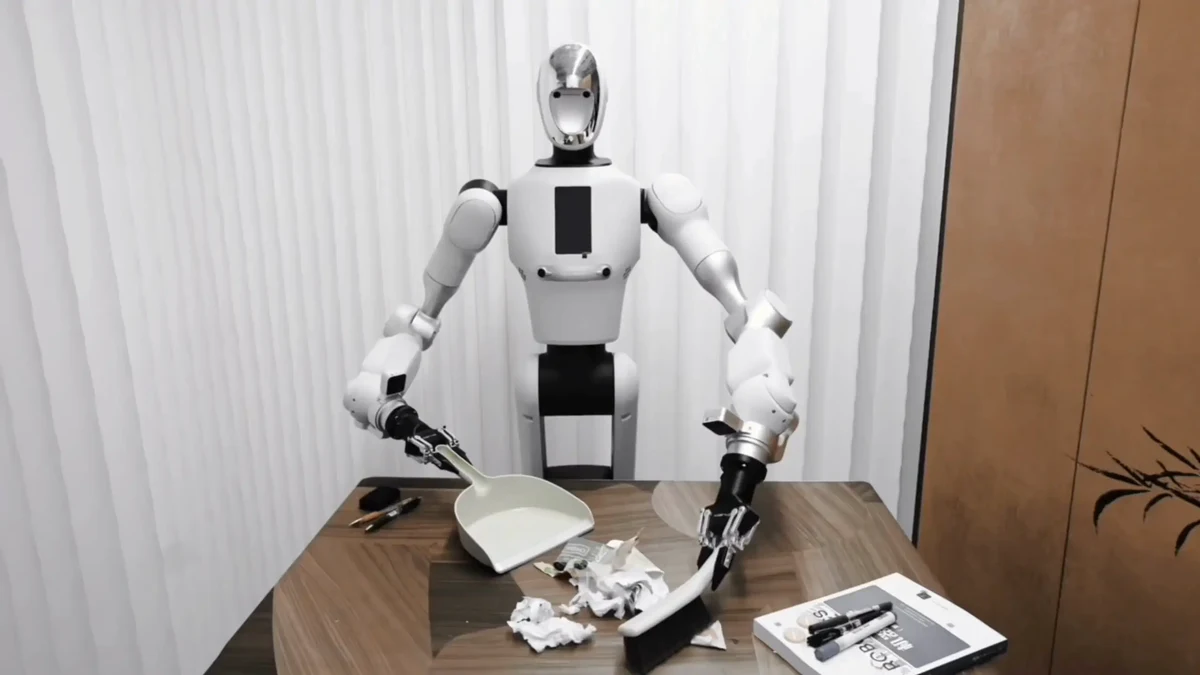
Hybrid Kinematics: 650 mm Torso Lift and Ground-to-Ceiling Reach
Operating inside real human work environments requires interacting with architectural layouts designed for human height variations. Fixed-height mobile bases frequently fail to reach bottom storage bins or upper supermarket display shelves without complex mechanical compromises.
Galbot engineers resolved this bottleneck through an integrated vertical lift column:
- Telescoping Torso Travel: A central 2-DOF lift column provides 650 mm of vertical elevation difference, adjusting the robot’s physical height dynamically between compact transit posture and full 1,730 mm extension.
- Ground-to-Ceiling Workspace: Paired with dual 710 mm articulated arms (7 DOF each), the robot achieves a wrist manipulation envelope spanning vertically from 0 mm (direct floor pickup) up to 2,100 mm (overhead warehouse shelving), with a horizontal span of 1,900 mm.
- Omnidirectional 4-Wheel Base: Measuring 600 mm by 600 mm with a circular turning envelope of 625 mm, the mobile chassis navigates tight store aisles at speeds up to 1.5 m/s (5.4 km/h), guided by an onboard 3D LiDAR, 8 ultrasonic sensors, and chassis inertial measurement units.
- Payload Capacity: The dual-arm architecture reliably handles 5 kg per arm (10 kg total payload) at the wrist center, sufficient for retail goods, automotive components, and pharmaceutical cases.
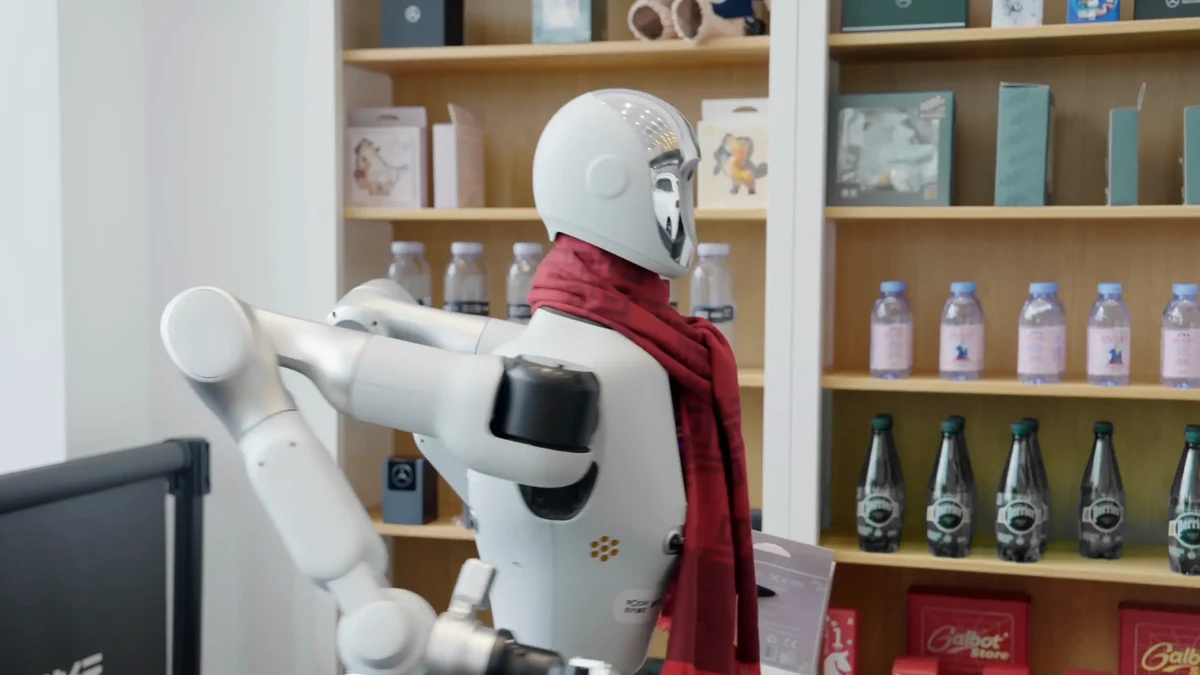
AstraBrain: End-to-End Embodied Physical AI
Hardware flexibility is only half the battle; real-world environments present unpredictable obstacles, reflective glass bottles, and misaligned packaging. Driving the G1 is AstraBrain, Galbot’s proprietary multimodal physical foundation model running locally on an onboard NVIDIA Jetson AGX Orin computing module (64 GB, delivering 275 TOPS of INT8 AI compute).
Rather than relying on brittle pre-programmed trajectory waypoints, AstraBrain executes a continuous closed-loop perception-decision-action cycle:
- Multimodal Visual Sensing: A binocular stereo head camera, four wide-angle torso RGB sensors, and dual wrist-mounted depth cameras generate an unobstructed 3D point cloud of the immediate workspace.
- Sub-Newton Tactile Feedback: Each 12-DOF articulated hand incorporates sensitive tactile arrays and wrist-mounted six-axis force sensors capable of detecting sub-Newton contact pressures, preventing the crushing of fragile blister packs or eggs.
- Dynamic Error Recovery: If an item slips or a customer shifts a container during grasping, the visual-tactile loop recalculates finger trajectory in milliseconds without crashing or requiring operator intervention.
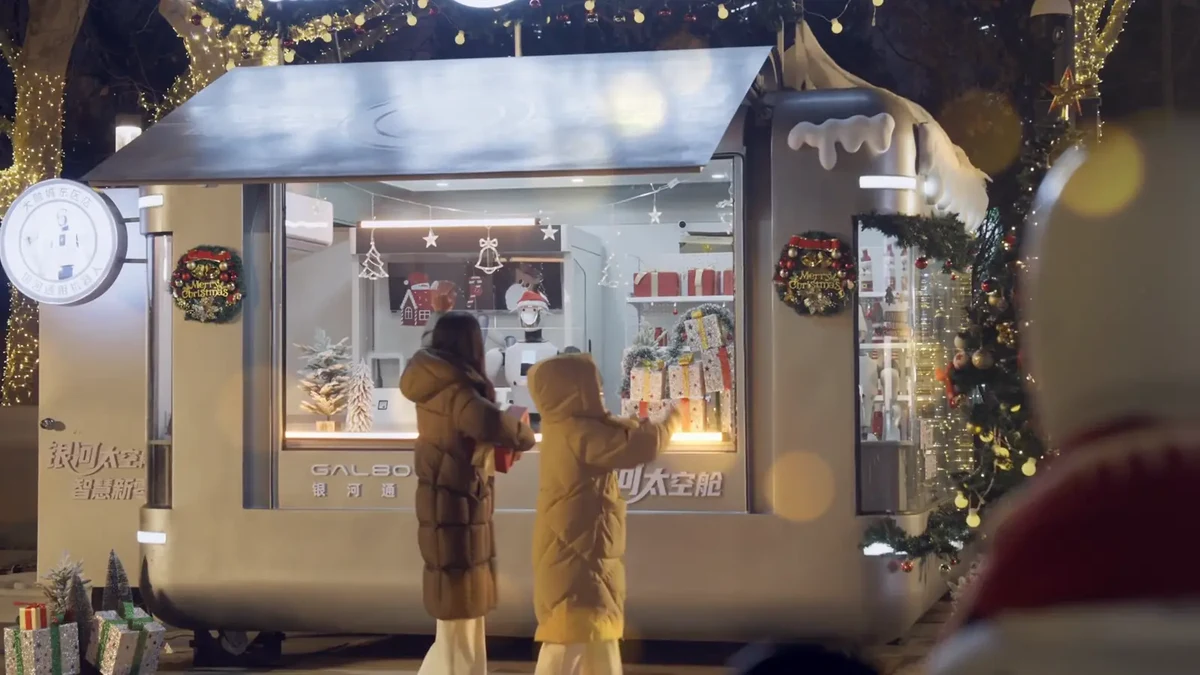
Urban Deployment: Over 170 Commercial Sites Across 40 Cities
Unlike early-stage pilot prototypes that run short choreographed demonstrations, the Galbot G1 boasts an extensive verifiable commercial track record:
- Galbot Space Capsules: Over 170 unstaffed convenience kiosks operate across more than 40 cities in China, where G1 units independently manage inventory sorting, order picking, and customer handovers 24 hours a day.
- Instant Retail Warehouses: Commercial fulfillment depots have deployed G1 fleets continuously for over 18 months, maintaining an autonomous shift success rate exceeding 98%.
- Automotive and Electronics Manufacturing: Industrial collaborations with global tier-one enterprises including Bosch, CATL, and Toyota leverage the G1 for component kitting, machine tending, and internal warehouse parts replenishment.
Powered by a 48V 30Ah lithium battery pack (1,440 Wh), the G1 sustains 8 hours of active shift work, with rapid 3.5-hour recharge cycles. By demonstrating commercial viability at scale, Galbot is proving at Web Summit that the fastest route to profitable robotic labor lies in combining human-like dexterity with stable, wheeled mobility.