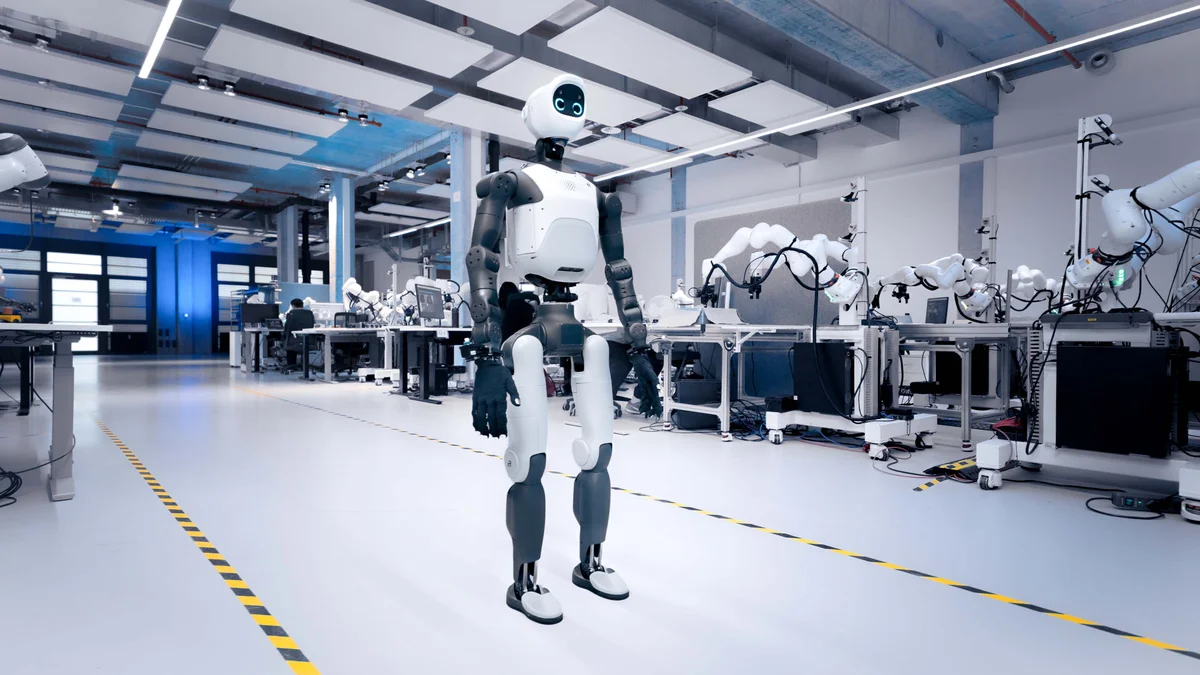
 R&D Reference Humanoid / NVIDIA GTC 2026 LaunchDE • 2026
Agile ONE SN
Agile Robots • Germany
« Compact German Physical AI reference humanoid powered by NVIDIA Jetson Thor and Isaac GR00T. »
Who is this robot built for? (Procurement Verdict)
Notre analyse indépendante basée sur les retours d'ingénieurs terrain, les tests en conditions réelles et les contraintes d'infrastructure.
Ideal Profile & Recommended Use Cases
- ✓Frontier Physical AI research using end-to-end NVIDIA Isaac GR00T foundation models
- ✓High-dexterity manipulation experiments requiring 20 DoF tactile force-controlled hands
- ✓Fast-track simulation-to-reality pipelines combining Isaac Sim, Isaac Lab, and Jetson Thor compute
Key Caveats & Who Should Avoid It
- ✕Heavy industrial lifting exceeding 3 kg payload capacity per arm
- ✕Consumer household domestic chores or untethered outdoor off-road traversal
- ✕Budget-constrained student labs requiring sub-$20k disposable educational robots
Procurement Reality & Commercial Availability : Comment l'obtenir concrètement ?
Agile Robots Direct & NVIDIA Partner Network
Field Reality: AI Autonomy vs Teleoperation
Assessment of real-world operational independence versus human supervision.
💡 Synthèse SpecsLib : Zero-shot physical AI policy execution via onboard Jetson Thor edge computing and Isaac GR00T
Confirmed 100% Autonomous Capabilities
- ✓Bipedal locomotion and whole-body balance control on level indoor flooring
- ✓Vision-language-action (VLA) object identification and container bin-picking
- ✓Tactile force-feedback closed-loop grasp adjustment at 1 kHz
- ✓Isaac Lab policy transfer validation across synthetic digital twin environments
Tasks Requiring Teleoperation or VR Supervision
- ⚠Data collection and imitation learning teleoperation via VR headset or mocap suit
- ⚠Manual override for unmodeled factory floor hazards and novel component geometries
Cinématique & Moteurs
Subsystem breakdown of degrees of freedom (DoF) and actuation torque.
- Total DoF
- 71 DoF
- Hands & Fingers
- 40 DoF
- Arms
- 14 DoF
- Legs
- 12 DoF
- Torso & Neck
- 5 DoF
- Actuator Type
- Proprietary High-Torque DLR-Derived Electric Actuators
Capteurs & Calculateurs
Perception cameras, onboard AI compute hardware, and power management.
- Vision Perception
- Head-Mounted RGB-D Depth Cameras & Wrist-Mounted Close-Range Cameras
- LiDAR Sensing
- Oui (3D LiDAR)
- Compute Architecture
- NVIDIA Jetson Thor (2,070 FP4 TFLOPS, 128 GB Unified Memory)
- Embedded AI Model
- NVIDIA Isaac GR00T 1.7 Open VLA Model & Whole-Body Motion Control
Énergie & Charge
Capacité du pack lithium et charge utile admissible.
- Battery Pack
- N/A
- Endurance Runtime
- N/A
- Total Payload
- N/A
- Single Hand Payload
- 3 kg
- Charging Interface
- Internal Battery Pack & Continuous Bench DC Tether
Frequently Asked Questions & Expert Answers : Agile ONE SN
Everything you must know before evaluating or acquiring this platform.
1What makes the Agile ONE SN different from the standard Agile ONE?
The Agile ONE SN is a compact 1.40 m, 43 kg reference humanoid designed specifically for R&D labs and academic researchers, preconfigured with NVIDIA Isaac GR00T and onboard Jetson Thor compute. The full-size Agile ONE is a larger 1.74 m, 69 kg industrial robot optimized for factory production lines, though skills trained on the ONE SN transfer directly to the full-size platform.
2What role does the NVIDIA Jetson Thor platform play in the robot?
Jetson Thor serves as the onboard edge supercomputing brain, providing 2,070 FP4 TFLOPS of compute and 128 GB of unified memory. It processes multimodal perception streams in real time, executes GR00T 1.7 Vision-Language-Action (VLA) models, and drives whole-body torque control without relying on external cloud latency.
Recommended Head-to-Head Duels
Confront this robot directly against other market leaders with 1-click comparison: