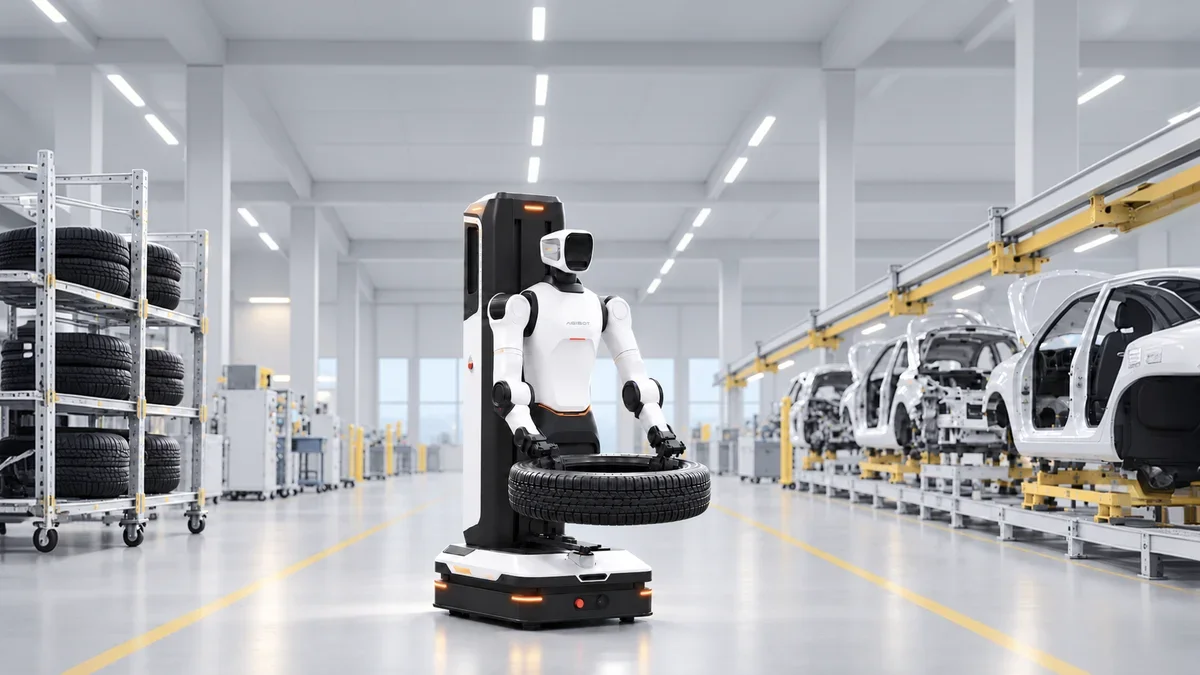
At AGIBOT Innovation Day 2026 in Shanghai, Chinese embodied artificial intelligence pioneer AGIBOT delivered an engineering roadmap that shifts the humanoid robotics industry from prototype delivery counts to measurable, autonomous physical work. Led by Co-founder, President, and CTO Peng Zhihui, the company unveiled AHA3 (AGIBOT Humanoid Architecture 3), launched the heavy-duty G2 Max industrial mobile manipulator, introduced the GO-3 Preview foundation model, and proposed Worken, a standardized industrial metric designed to quantify effective robot labor.
Coming off the milestone of 20,000 commercial robots manufactured across its lines, AGIBOT presented full-scale production deployments across automotive suppliers, electronics assembly hubs, and public infrastructure, establishing physical AI as an operational reality rather than a staged exhibition.
AHA3 Hardware Architecture: Liquid Cooling and IP67 Industrial Hardening
A central engineering reveal was AHA3, AGIBOT’s third-generation commercial hardware architecture. Built on a “Three Intelligences in One” design philosophy, AHA3 establishes a shared physical and electronic backbone uniting locomotion intelligence, interaction intelligence, and manipulation intelligence into a single unified chassis.
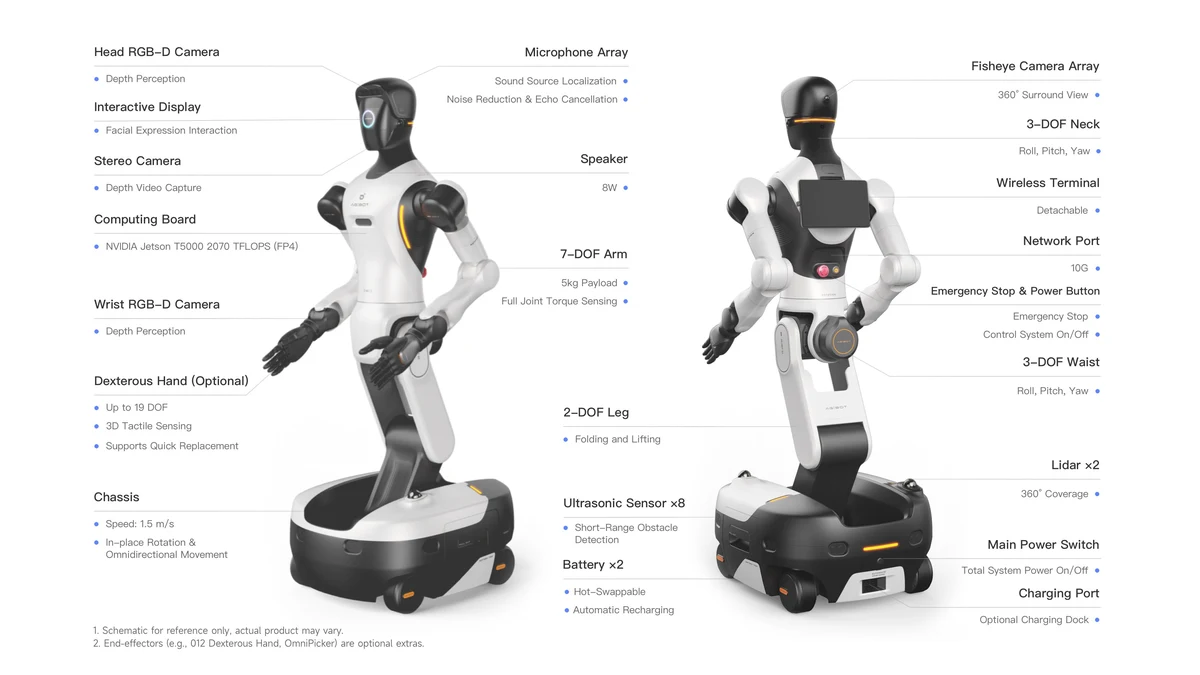
To overcome the persistent thermal dissipation limits that have historically triggered thermal throttling during prolonged industrial cycles, AHA3 introduces a dedicated joint liquid-cooling system. Operating in tandem with specialized IP67-rated joint enclosures, the cooling architecture protects harmonic reducers and planetary drives against continuous heat buildup, dust ingress, and factory fluids.
AHA3 also standardizes high-speed connectivity via native Wi-Fi 6 and 5G modules, alongside an updated end-effector lineup comprising the OmniHand 3 Lite, OmniHand 3, OmniHand 3 Ultra, and the OmniPicker 3 tactile gripper for high-throughput logistics lines.
G2 Max: 50 kg Heavy-Duty Industrial Mobile Manipulation
Targeting heavy manufacturing, pallet depalletizing, and CNC machine tending, AGIBOT formally launched the G2 Max. Combining an omnidirectional four-wheel steering chassis with a heavy-duty humanoid dual-arm torso, the platform delivers high-cadence manipulation across factory floors.
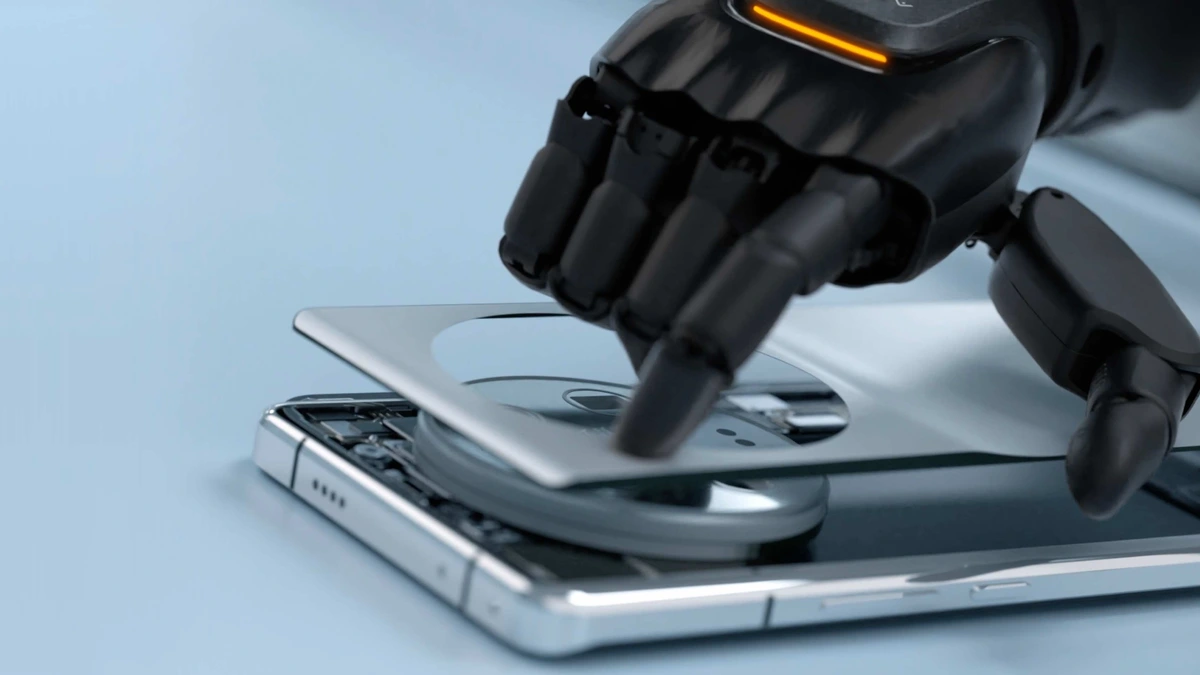
The technical specifications of the G2 Max establish it among the highest-capacity mobile manipulators in active production:
- Dual-Compute Architecture: Onboard inference is driven by the NVIDIA Jetson Thor (T5000) module delivering 2,070 TFLOPS (FP4) for local Vision-Language-Action (VLA) execution under 10 ms latency, coupled with a secondary Rhino R1 processor (500 TOPS) managing deterministic joint servoing, odometry, and obstacle avoidance.
- Payload Capacity: Engineered for continuous dual-arm handling of 40 kg (20 kg per arm), with an instantaneous peak payload mode reaching 50 kg.
- Working Envelope: A vertical manipulation reach extending from 0.1 m to 2.5 m, allowing the robot to pick crates directly from floor pallets up to multi-tier warehouse racking.
- Precision and Mobility: Arm repeat positioning accuracy of ±0.5 mm, integrated with four-wheel crab-steering enabling zero-radius rotation in narrow production corridors at speeds up to 1.5 m/s.
- Power Continuity: Dual hot-swappable battery modules paired with automated inductive base docking for continuous 24/7 operating cycles.
GO-3 Preview and WITA-Omni Foundation Models
On the software layer, AGIBOT debuted GO-3 Preview, an embodied foundation model built on its proprietary WRAM (World Reasoning Action Model) architecture. Unlike purely cognitive language models, WRAM connects task comprehension, future-state prediction, and real-time action generation.
WRAM integrates three foundational algorithmic mechanisms:
- CoAE (Control-Oriented Autoencoder): Preserves fine spatial geometry, camera-to-joint transforms, and object depth maps.
- SVP (Single-step Virtual Prediction): Generates one-step forward world states to anticipate dynamic changes before initiating motion.
- KASO (Kinematically Aligned Selected Outcomes): Prunes non-physical trajectory branches to maintain dynamic joint torque limits.
In rigorous benchmark evaluations, GO-3 Preview secured first place across three prominent embodied AI benchmarks: RoboDojo, RoboTwin, and RoboColiseum. AGIBOT committed to open-sourcing the full model weights by the end of 2026 alongside Link-U OS 1.0, donated to the OpenAtom Foundation. Complementing manipulation, the WITA-Omni 1.0 model provides full-duplex conversational interaction with zero-latency human interruption handling and synchronized expressive head displays.
The Worken Metric: Redefining Physical AI Productivity
To establish an objective economic framework for robot labor, AGIBOT introduced Worken (combining “Work” and “Token”). Rather than evaluating deployments by raw unit counts, Worken measures Effective Intelligent Work Hours through a standardized equation:
Worken = Number of Active Robots × Autonomous Working Hours × Output Efficiency RatioBy discounting standby time and scaling output against verified human labor baselines, Worken provides industrial facility managers with an audited metric for capital expenditure and total lifecycle value.
Supported by active deployments at Longcheer manufacturing cells, Guangzhou Metro stations, and Chimelong entertainment hubs, AGIBOT’s hardware and software stack illustrates that the embodied robotics race in late 2026 has transitioned from academic proof-of-concept into hardened, around-the-clock factory execution.
For industrial engineers evaluating mobile wheeled manipulation against bipedal logistics platforms, explore our head-to-head comparison between the Agibot G2 Max vs Agility Digit 5, review the flagship Agibot A3, or consult the complete Agibot G2 Max Engineering Dossier.